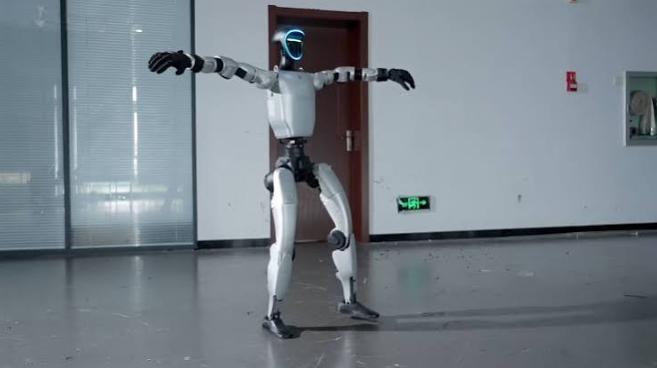
Humanoid robots are becoming increasingly sophisticated as engineers work to improve their mobility, balance, precision, and ability to operate alongside people. These machines must support motors, sensors, batteries, control systems, and mechanical joints while maintaining a manageable overall weight. Choosing appropriate structural materials is therefore a major part of robot design.
A robot’s frame influences far more than its appearance. It affects energy consumption, joint loading, movement speed, thermal management, and the amount of payload the machine can carry. Materials must also withstand repeated movement, vibration, and occasional impacts without developing excessive deformation or fatigue damage.
Aluminum is an attractive option for many robotic structures because it offers a useful combination of low density, machinability, corrosion resistance, and mechanical performance. Understanding where it works best, and where other materials may be preferable, helps engineers develop more efficient and dependable humanoid systems.
Why Material Selection Matters in Humanoid Robotics
A humanoid robot has a demanding mechanical architecture. Its torso supports major electronic systems, its limbs move through multiple joints, and its hands may need to manipulate objects with considerable precision. Every structural component contributes to the machine’s weight and mechanical behavior.
Reducing unnecessary mass can improve several aspects of performance. Lighter limbs generally require less torque to accelerate and decelerate, which may reduce demands on motors, gearboxes, and power systems. Lower structural mass can also make balance control easier, although the final effect depends on the robot’s mass distribution and control strategy.
Material selection must still account for stiffness, strength, fatigue resistance, manufacturability, and cost. A lightweight component that bends excessively or wears prematurely can create more problems than it solves.
The Relationship Between Weight and Energy Consumption
Robots use energy to move their limbs, maintain balance, and operate their onboard electronics. Structural weight influences the mechanical work required for movement, particularly when the robot repeatedly lifts its arms or legs.
Reducing the mass of moving components can lower the energy needed for acceleration. The benefits are especially relevant for distal limb sections, such as forearms and lower legs, because their mass can influence the torque required at joints farther up the limb.
However, lower weight does not automatically guarantee longer operating time. Motor efficiency, battery capacity, control algorithms, walking patterns, and payload requirements also influence energy consumption.
Stiffness and Precision
Structural stiffness matters whenever a robot must position tools, hold objects, or coordinate movements accurately. Excessive deflection can create errors between the intended position and the actual position of a component.
Engineers must therefore balance weight reduction against the need for rigidity. Material thickness, cross-sectional shape, joint placement, and reinforcement can all influence stiffness.
A well-designed aluminum component may achieve the necessary performance with less mass than a comparable steel part, but the result depends on geometry and loading conditions rather than material density alone.
The Role of Aluminum in Robotic Structures
Aluminum alloys are used in many engineered products because they combine relatively low density with a range of mechanical properties. Different alloy families offer different balances of strength, formability, corrosion resistance, and machinability.
For robotics, these characteristics make aluminum useful for selected frames, brackets, housings, mounting plates, and structural covers.
Lightweight Construction
Aluminum has a density of approximately 2.7 grams per cubic centimeter, substantially lower than that of steel. This difference can help reduce the mass of structural components when the design is optimized appropriately.
Engineers may use aluminum plates to create mounting surfaces, support brackets, and enclosure panels. In some designs, machining pockets or using carefully engineered ribs can remove unnecessary material while preserving required stiffness.
The final design must still account for stress concentrations, fastener loads, and deformation under dynamic forces.
Corrosion Resistance
Aluminum naturally forms a thin oxide layer that helps protect the underlying metal from corrosion. This characteristic can be useful for robots operating in varied indoor environments or exposed to occasional moisture.
Corrosion resistance is not absolute. Certain chemicals, salt exposure, dissimilar-metal contact, and unsuitable cleaning methods can create problems. Surface treatments, protective coatings, and appropriate fastener selection may be necessary in demanding environments.
Machining and Fabrication
Aluminum can be cut, drilled, milled, and formed using established manufacturing methods. This flexibility allows engineers to develop complex brackets and mounting structures that accommodate sensors, cables, actuators, and electronic modules.
Manufacturing tolerances are particularly important around joints and precision interfaces. Poorly controlled machining can introduce alignment errors that affect motion accuracy or accelerate wear.
Design teams should also consider how parts will be assembled, serviced, and replaced throughout the robot’s operating life.
Selecting Suitable Aluminum Alloys
Not all aluminum alloys provide the same performance. The choice should reflect the component’s loading conditions, geometry, manufacturing process, and environmental exposure.
Strength and Machinability
Certain heat-treatable aluminum alloys offer relatively high strength and good machinability, making them candidates for selected brackets, mounting plates, and load-bearing components.
Other alloys may be preferable where forming, welding, or corrosion resistance is more important. Engineers should compare verified material properties rather than selecting an alloy based only on its general reputation.
Mechanical properties can also depend on temper, sheet thickness, processing history, and the direction in which loads are applied.
Fatigue Resistance Under Repeated Movement
Humanoid robots undergo repeated cycles of walking, reaching, lifting, and turning. These actions can expose structural parts to fluctuating loads that eventually cause fatigue damage.
Components near joints and fasteners may experience concentrated stresses. Engineers should evaluate fatigue behavior, use suitable design factors, and avoid sharp transitions that increase local stress.
Prototype testing under representative movement patterns can reveal weaknesses that static calculations alone may not identify.
Thermal and Electrical Considerations
Aluminum conducts heat effectively, which can help dissipate heat from selected electronic housings and motor-related structures. This property may be useful where thermal management is a design priority.
Its electrical conductivity also requires careful attention when designing enclosures around sensitive electronics. Insulation, grounding, and electromagnetic compatibility should be addressed as part of the complete system design.
Aluminum’s thermal expansion must also be considered when components are assembled with materials that expand differently.
Where Aluminum Sheets Fit Into Humanoid Robot Design
Sheet aluminum is particularly useful when engineers need lightweight panels or components that can be cut and shaped to fit a specific assembly.
Chassis Panels and Equipment Enclosures
Structural panels and covers can protect internal components while providing mounting surfaces for cables, sensors, and electronics. Aluminum sheets may be used in selected torso panels, access covers, and equipment enclosures.
These components should be designed to withstand expected vibration and impact. Thin panels may need formed edges, ribs, or additional supports to prevent excessive flexing.
Mounting Plates and Brackets
Robotic assemblies often require custom plates for motors, sensors, gearboxes, and control hardware. Aluminum sheet and plate products can be machined into these components, depending on the required thickness and tolerances.
Mounting surfaces must remain sufficiently stable under operating loads. Engineers should verify fastener strength, hole spacing, edge distances, and the effects of repeated assembly.
Prototype Development
Early robot development often involves frequent changes to component layouts. Aluminum components can be useful for prototypes because established cutting and machining processes allow engineers to revise designs without developing entirely new production systems.
During this stage, aluminum sheets for humanoid robots may be considered for selected structural panels and custom mounting components, provided the alloy, thickness, and manufacturing method meet the project’s requirements.
Prototype success should not replace formal validation. Parts intended for repeated operation need appropriate fatigue, impact, and dimensional checks before entering service.
Aluminum Compared With Other Engineering Materials
Aluminum is not automatically the best choice for every robotic component.
Steel provides higher stiffness and often greater strength at a given cross-sectional size, although its higher density can increase the weight of the finished assembly. It may remain appropriate for heavily loaded shafts, gears, and selected joint components.
Carbon-fiber composites can offer excellent stiffness-to-weight performance in particular directions. However, they may require more specialized manufacturing, careful joint design, and additional attention to impact damage.
Engineering plastics can reduce weight and provide electrical insulation in selected covers and housings. Their temperature limits, creep behavior, and mechanical properties must be evaluated for the intended operating conditions.
The most effective humanoid robots often use a combination of materials. Aluminum may provide the main structure, steel may be used in highly loaded mechanisms, and polymers may serve as protective covers or electrical insulators.
Common Design Mistakes to Avoid
One mistake is reducing material thickness without checking stiffness and fatigue performance. A lighter component may deform under load or develop cracks around mounting holes.
Another is choosing an alloy without considering the manufacturing process. Welding, forming, and machining can affect final properties and dimensional accuracy.
Engineers should also avoid overlooking connections between different materials. Galvanic corrosion may occur when aluminum contacts certain other metals in the presence of an electrolyte, while differences in thermal expansion can introduce stress during temperature changes.
Finally, a component should not be judged only by its static strength. Walking, sudden stops, repeated lifting, and accidental collisions create dynamic loading conditions that require appropriate analysis and testing.
A Practical Framework for Material Selection
A reliable selection process starts with defining the component’s function. Determine the loads it must support, the available space, the required stiffness, and the expected service environment.
Next, compare suitable alloys using verified mechanical and manufacturing data. Evaluate whether sheet fabrication, machining, forming, or another process provides the best balance of cost, precision, and production volume.
Create prototypes when necessary and test them under realistic conditions. Measurements of deformation, vibration, temperature, and wear can help identify improvements before production begins.
Engineers should also consider the complete lifecycle. Replacement availability, repairability, manufacturing waste, and recycling options may affect the overall value of the selected material.
Three Common Questions
1. Why is aluminum useful in humanoid robots?
Aluminum offers relatively low density, useful mechanical properties, corrosion resistance, and established fabrication methods. These characteristics make it suitable for selected frames, mounting plates, panels, and enclosures when the design meets the required strength and stiffness.
2. Which aluminum alloy is best for robotic components?
There is no single best alloy for every component. Selection depends on required strength, fatigue performance, corrosion resistance, machinability, forming or welding needs, and operating conditions. Engineers should use verified data for the exact alloy and temper.
3. Can aluminum sheets be used for load-bearing robot structures?
They can be used in certain structural applications, but suitability depends on thickness, geometry, alloy properties, loading, and joint design. Structural calculations and prototype testing are necessary when component failure could affect robot safety or reliability.
Conclusion
Material selection has a significant influence on the performance, efficiency, and durability of humanoid robots. Aluminum provides a useful balance of weight, strength, corrosion resistance, and manufacturability, making it suitable for many panels, brackets, housings, and structural components.
Successful designs require more than selecting a lightweight metal. Engineers must consider alloy properties, component geometry, fatigue loads, manufacturing tolerances, and connections with other materials. By combining careful analysis with practical testing, development teams can create robotic structures that meet performance requirements without adding unnecessary mass or cost.